Research Output
Publications by Kind
- Journal Articles20
- Conference Papers51
- Workshop Papers5
- Book Chapters1
- Theses6
Activity per Year
Latest Awards
Latest Publications
大規模言語モデルによる複数ロボットの知識統合とタスク割当を用いた現場学習のコスト削減
Journal of the Robotics Society of Japan (JRSJ)
2025 · International conference article, peer-reviewedPublic Evaluation on Potential Social Impacts of Fully Autonomous Cybernetic Avatars for Physical Support in Daily-Life Environments: Large-Scale Demonstration and Survey at Avatar Land
Proceedings of 2025 IEEE International Conference on Advanced Robotics and its Social Impacts (ARSO 2025)
2025 · International journal article, peer-reviewedA Gesture-based Behaviour-driven Development Approach for End-User Cobot Programming
Robotica
Biography
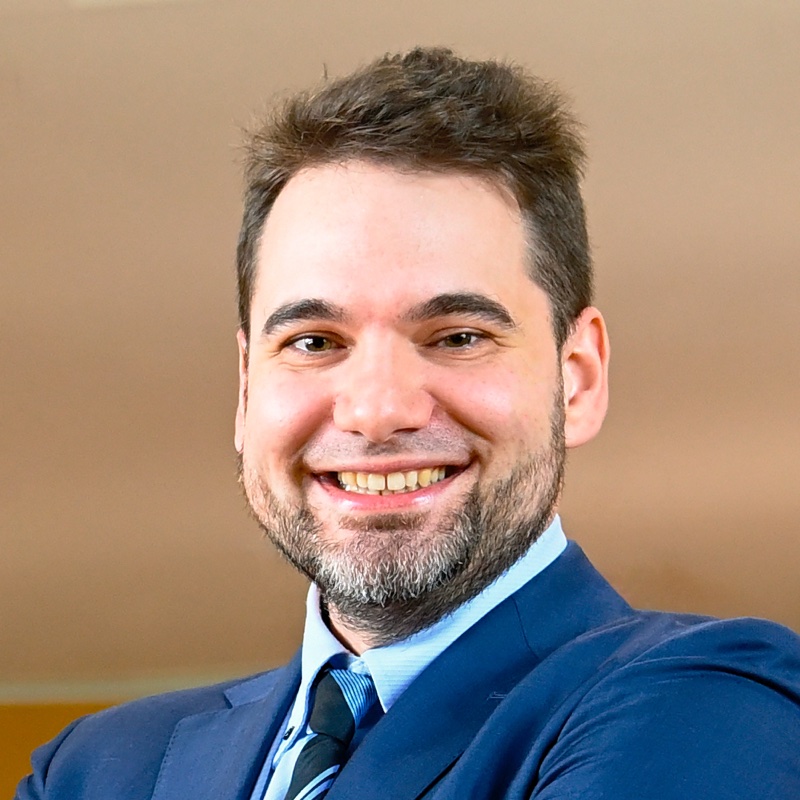
Lotfi El Hafi, PhD, is a Research Associate Professor at Ritsumeikan University, Japan, and the President & Founder of Coarobo GK, Japan.
He received his MScEng in Mechatronics from the Université catholique de Louvain (UCLouvain), Belgium, in 2013, and his PhD in Engineering from the Nara Institute of Science and Technology (NAIST), Japan, in 2017. His master’s thesis contributed to TICO compression, now standardized as JPEG XS, for Ultra HD 4K/8K video distribution during an internship at intoPIX SA, Belgium, and later as a Sales Engineer while completing the AWEX International Business & Management EXPLORT Program. He then joined the Robotics Laboratory at NAIST as a recipient of the MEXT Scholarship in 2014. His PhD thesis proposed a novel eye-tracking method, “Simultaneous Tracking and Attention Recognition from Eyes (STARE),” which leveraged deep learning to extract behaviors from scene images reflected in the eyes, earning him the “Best of IET and IBC 2016–2017.”
He joined the Ritsumeikan Global Innovation Research Organization (R-GIRO) of Ritsumeikan University, Japan, for the “International and Interdisciplinary Research Center for the Next-Generation Artificial Intelligence and Semiotics (AI+Semiotics)” project as a Senior Researcher in 2017, later becoming Research Assistant Professor in 2019. His research activities included service robotics, AI, and system integration, with a particular interest in multimodal interaction in extended reality (XR). In this regard, he received 2 research awards from JST CREST: the “Best Award for Research Proposal Breaking Hagita-CREST Shell: Visualization of Emergent Reality in Robotics for Future Harmonious Interaction” and the “Best Award for Forecasting Research Proposal: Toward Early Realization of Harmonious Human-Robot Interaction.”
He has also won numerous international robotics competition prizes, including the “1st Place” in the Airbus Shopfloor Challenge at IEEE ICRA 2016, the “Finalist Prize” in the Amazon Robotics Challenge 2017, the “NEDO Chairman’s Award for Excellence in World Robot Summit 2018,” the “SICE Award for WRS Future Convenience Store Challenge 2018,” the “METI Minister’s Award for Excellence in World Robot Summit 2020,” the “2nd Place Regional Prize in Eastern Asia + South Eastern Asia” in the OpenCV AI Competition 2021, and multiple “1st Places” in the WRS Future Convenience Store Challenge since 2018, including one at IEEE/RSJ IROS 2022. These contributions addressed both the technological and theoretical challenges of super-smart societies (Society 5.0), in collaboration with the Robotics Hub of Panasonic Corporation, Japan, where he has served as a Research Advisor for Robotics Competitions since 2019. There, he contributed to the development of AMIS, or “Autonomous Manipulation for Intelligence Services,” a human-centered robotic platform, also in collaboration with NAIST.
His recognized achievements in competitions also led to his appointment as a Specially Appointed Researcher of HSR Community by Toyota Motor Corporation, Japan, from 2020 to 2022, during which he developed a containerized Software Development Environment (SDE) using cloud-first, open-source technologies to accelerate cross-institutional collaborative R&D. More than 20 institutions across Japan and the EU are known to have tested the SDE, with half adopting it for research. This endeavor earned him the inaugural “HSR Community Research Encouragement Award” from RSJ in 2022.
He has held the position of Research Associate Professor at the Research Organization of Science and Technology of Ritsumeikan University, Japan, since 2023. His contributions to the development of large-scale cognitive architectures for the JST CREST project “Symbol Emergence in Robotics for Future Human-Machine Collaboration” and the JST Moonshot R&D Program “The Realization of an Avatar-Symbiotic Society where Everyone Can Perform Active Roles without Constraint” have led him to investigate the mechanisms of multimodal robot learning in XR. His recent work on probabilistic inference and contrastive learning for service robots received the “Best Paper Awards” at IEEE/SICE SII 2023 and IEEE IRC 2024, respectively.
Over the years, he has authored over 80 academic publications and holds an h-index of 13 on Google Scholar, with more than 450 citations. He has helped build a vibrant research environment at Ritsumeikan University through successful grant applications as a Principal Investigator, including a competitive JSPS KAKENHI Grant-in-Aid for Early-Career Scientists titled “Emergent Reality: Knowledge Formation from Multimodal Learning through Human-Robot Interaction in Extended Reality,” securing over 15 million JPY in cumulative internal and external funding. He also informally supervises graduate students and international interns in the Emergent Systems Laboratory at Ritsumeikan University and has formally supervised 4 international master’s theses with UCLouvain.
He is an active member of IEEE (since 2015) and RSJ (since 2017), and a former member of JSME (2017–2022). He has peer-reviewed over 35 manuscripts for prestigious journals and conferences and served as Associate Editor for IEEE RO-MAN 2021 and Publicity Chair for IEEE/SICE SII 2026. Finally, he is the President & Founder of Coarobo GK, Japan, which provides containerized SDE solutions for researchers and developers in the fields of service robotics and AI.
[Last updated: June 2025.]
Profiles & Contact
Scholar
- Zotero
- ORCID
0000-0001-9795-6153 - Google Scholar
tsm7qaQAAAAJ - Scopus
- Web of Science
AAA-5833-2020 - Semantic Scholar
- Loop
- researchmap
B000302383 - KAKEN
90821554 - J-GLOBAL